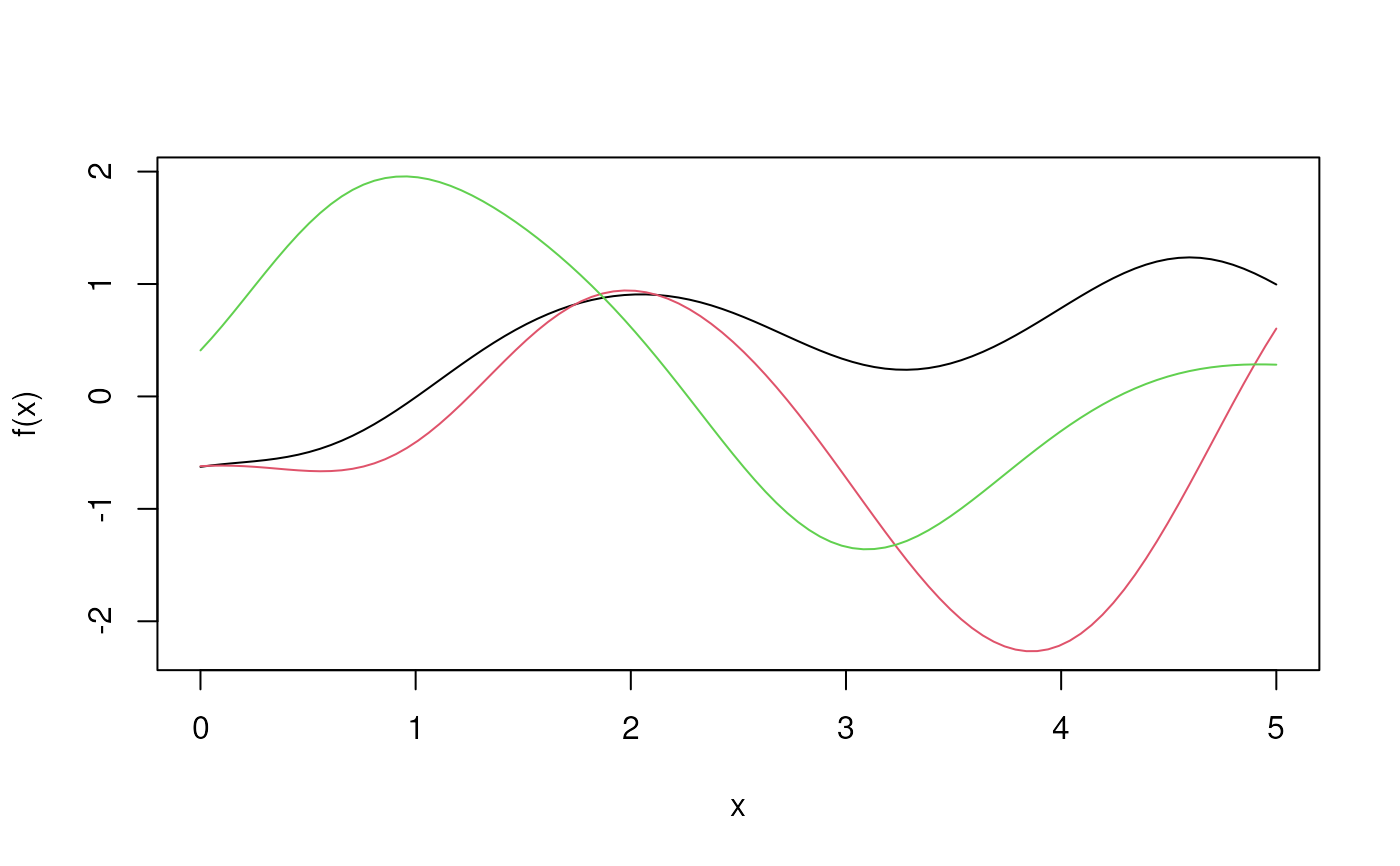
Draws latent function values \(f(x) \sim \mathcal{N}(m(x), K(x, x))\)
at the supplied inputs. Use simulate_gp_data() for a single prior draw
with added observation noise.
Arguments
- x
Numeric vector or matrix of inputs. Matrix rows are input points.
- kernel
A Gaussian-process kernel specification, including ARD and composite kernels.
- mean
Gaussian-process mean specification. Its coefficients must be fixed or have a Gaussian
coefficient_prior(), whose uncertainty the draws include.- n_draws
Number of independent function draws.
- seed
Optional non-negative integer seed. The caller's random state is restored afterwards.
- initial_jitter
Non-negative jitter tried first, relative to the covariance scale (the mean of its diagonal).
- fallback_jitter
Positive relative jitter tried after the first failed factorization.
- jitter_multiplier
Multiplicative jitter escalation factor.
- max_attempts
Maximum Cholesky attempts.
- symmetry_tolerance
Relative tolerance for checking that the covariance matrix is symmetric.
Value
An object of class gaussianprocesses_samples. Its latent
element is a matrix with one row per input point and one column per draw.
It also contains the prior mean, the latent_covariance that was
sampled, the numerical jitter, the relative_jitter and
covariance_scale it was computed from (jitter is relative jitter times
the mean diagonal of the covariance), and the cholesky_attempts.
Details
Each draw is \(m(x) + R^\top z\) with \(K(x, x) = R^\top R\) and
\(z \sim \mathcal{N}(0, I)\). Prior covariances on closely spaced inputs
are often numerically singular; the Cholesky factor then uses the package's
jitter policy, and the jitter is reported in the result. A single draw
with the same seed equals the latent values of simulate_gp_data().
Stability
Stable: from version 1.0.0 this interface changes incompatibly only in a major release, after a deprecation period. Results and options that concern an experimental model class, kernel, or argument follow that interface's tier. See gaussianprocesses-package for the policy.
Examples
x <- seq(0, 5, length.out = 100)
draws <- sample_gp_prior(x, rbf_kernel(length_scale = 0.8), n_draws = 3, seed = 1)
draws
#> Gaussian-process samples
#>   distribution: prior
#>   draws: 3 at 100 input point(s)
#>   contents: latent function draws
#>   numerical jitter: 1e-10 (1e-10 times the covariance scale 1)

matplot(x, draws$latent, type = "l", lty = 1, ylab = "f(x)")